Abstract
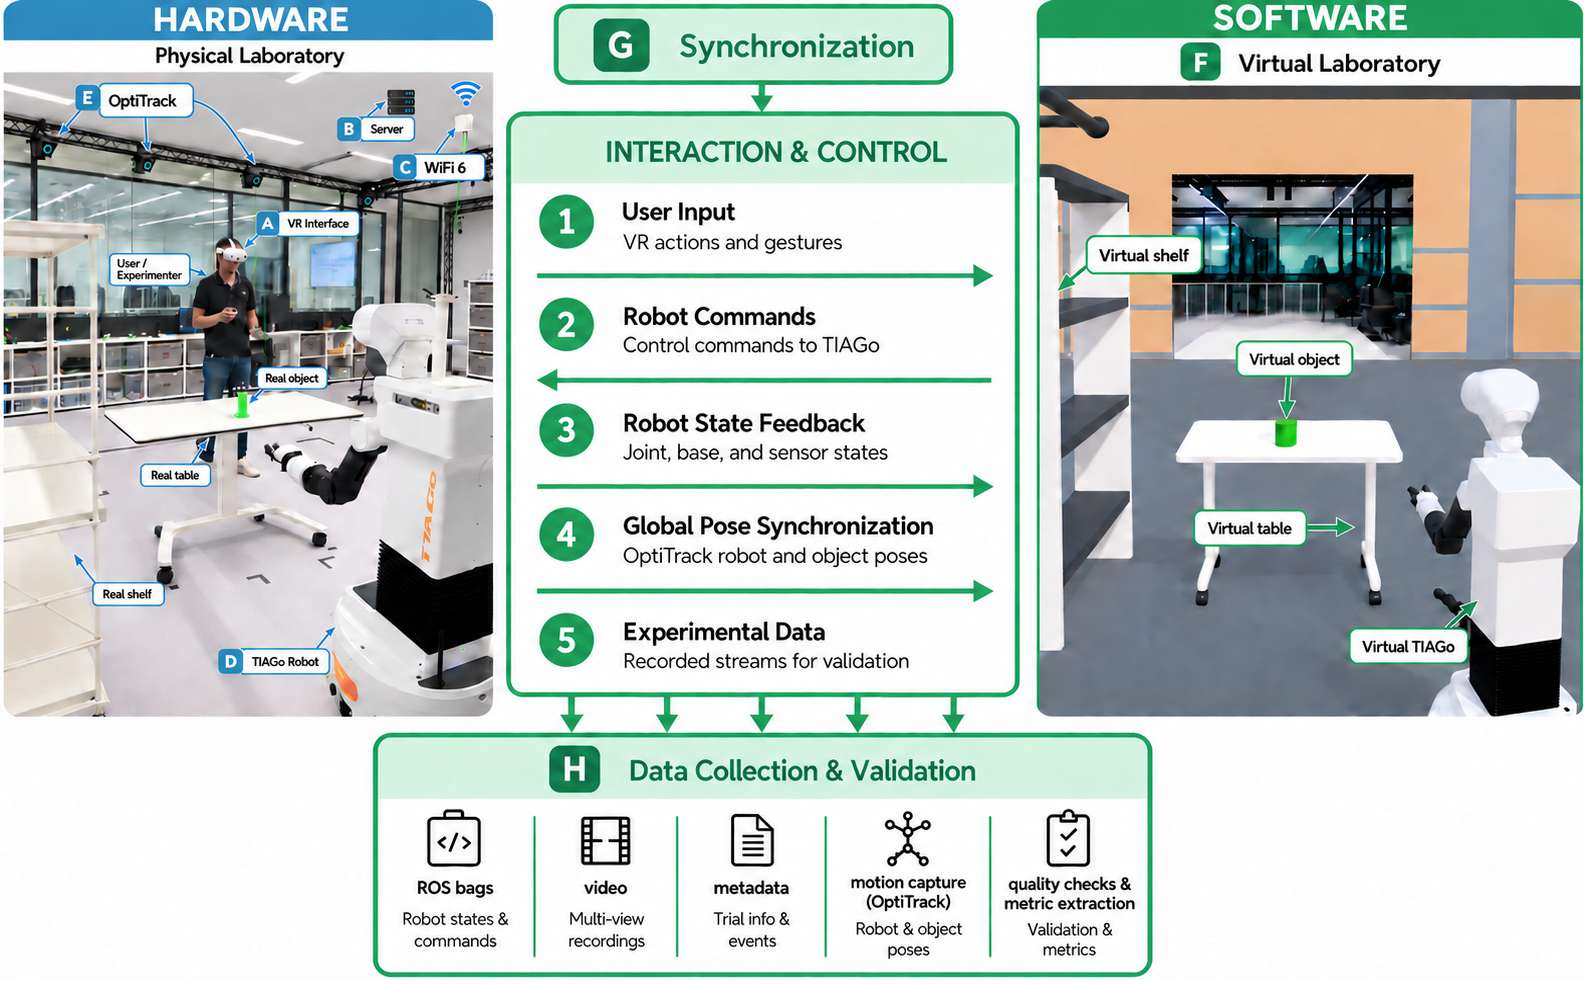
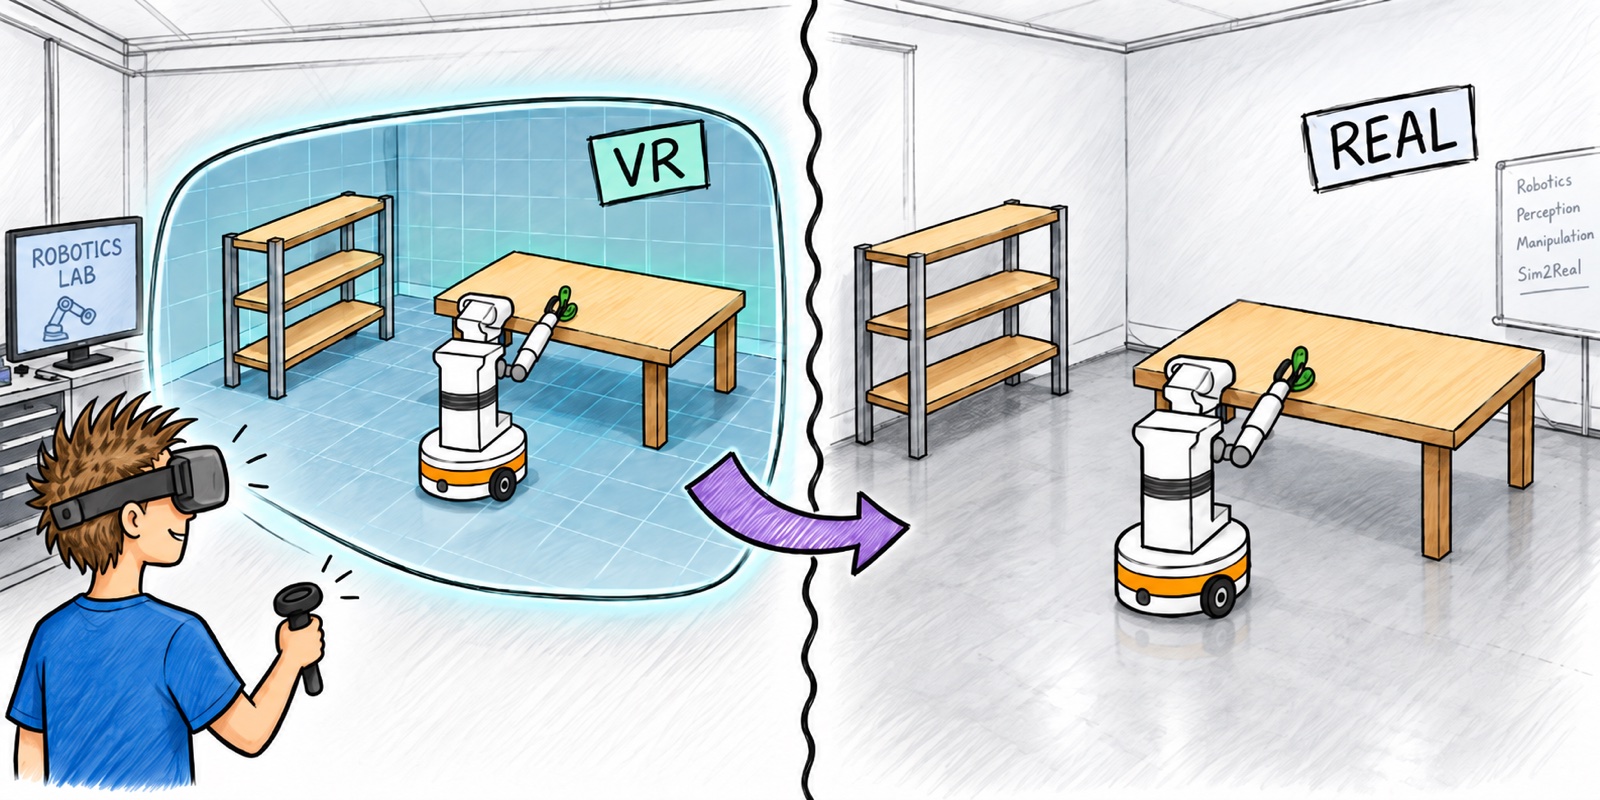
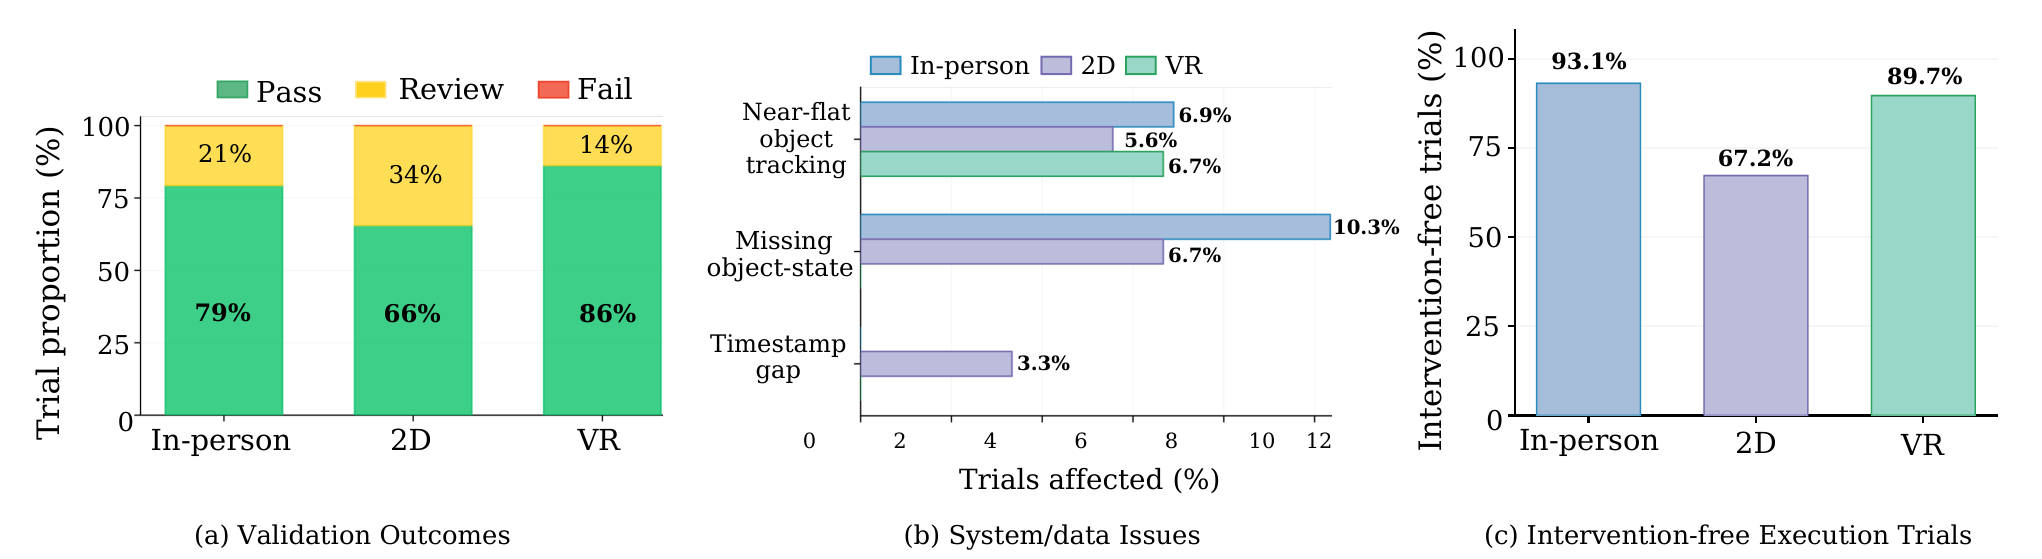
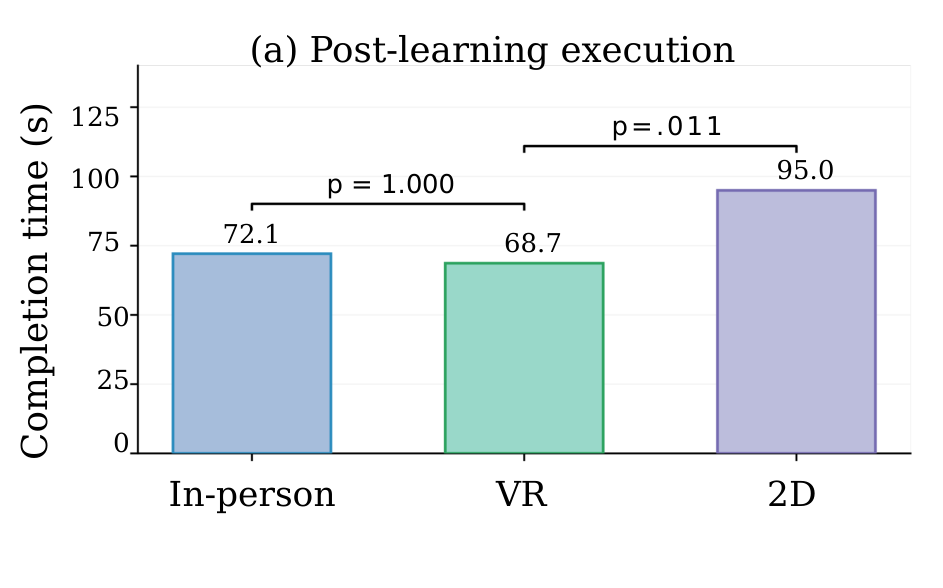
PUPPET is a cyber-physical framework for remote robotics experimentation that connects a physical laboratory to a continuously synchronized VR replica of the robot, surrounding environment, and task objects. By combining immersive teleoperation with an integrated trial validation pipeline, PUPPET enables users to remotely perform robotic experiments while ensuring the completeness and consistency of the resulting experimental data. The framework aims to bridge the gap between remote robot operation and reliable experimental data collection, making robotics laboratories more accessible while supporting the reproducibility and reusability of robotic experiments.
Gallery
Team Members
Eduardo Castelló Ferrer
Assistant Professor

Milan Groshev
Postdoctoral Associate

Mahika Vats
Graduate Research Assistant